Autonomous Mobile Archive Cabinet Robot System
Electromechanical robotic archive system integrating PLC motion control, Raspberry Pi hardware-software bridging, and RESTful APIs for automated document retrieval.
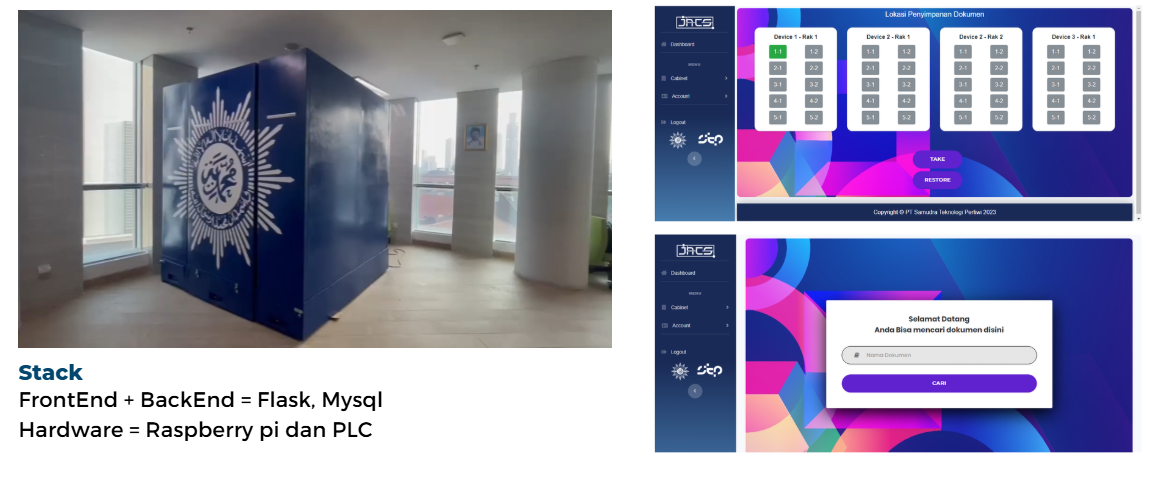
1. Context & Problem Statement
Developed for PT Samudra Teknologi Pertiwi, this autonomous mobile archive cabinet system automates physical document storage and retrieval. The project combines electromechanical motion mechanisms, industrial PLC controllers, microcomputer bridges, and a centralized web API.
2. System Architecture & Workflow
[Web Interface / ERP System]
             │ (HTTP / REST)
             ▼
[Raspberry Pi Gateway (Python / Flask)]
             │ (Modbus RTU over RS485)
             ▼
[Industrial PLC Controller (Omron / Mitsubishi)]
             │
     ┌───────┼───────┐
     ▼       ▼       ▼
[Motor Drive] [Sensors & Encoders] [Safety Interlocks / Estop]
3. Technical Highlights & Automation
• User Request: Operator inputs binder ID into terminal. • Coordinate Mapping: Backend translates binder ID to shelf coordinate (X, Y, Z). • Dispatch: Command sent via Modbus to PLC registers. • Motion Execution: Motor drives cabinet to open appropriate aisle; indicator lights guide operator; physical safety bumpers halt motion instantly on obstacle contact.
4. Measurable Results & Impact
Successfully deployed and demonstrated physical document automation, demonstrating reliable hardware-software co-design and industrial communication mastery.
Engineering Retrospective
In robotics, software reliability is only as good as the electrical grounding and mechanical safety interlocks underneath it.